|
I am a research scientist at Dyna, working on dexterous manipulation. I recently received my PhD in Computer Science from University of Illinois at Urbana-Champaign, where I was advised by Prof. Kris Hauser. I have dual undergraduate degrees in Computer Science from University of Michigan and Electrical and Computer Engineering from Shanghai Jiao Tong University. |
|
|
My research focuses on developing physically grounded models for robotic manipulation through multimodal real-world observations, including vision, touch, and language, with works in Robotic Manipulation [CVPR 2026, ICRA 2026 Workshop, ICRA 2025], Multimodal Perception [ICRA 2023, CoRL 2024, ICRA 2025] and Physical Modeling [ICRA 2024]. |
|
|
 |
Haowen Liu*, Xirui Li*, Shaoxiong Yao*, Peng Shi, Tianyi Zhou, Jia-Bin Huang, Furong Huang and Jiayuan Mao
arXiv preprint, 2026
vision-language modelstool-using agentsdistillationsim-to-real
|
 |
Shaoxiong Yao, Chengyi Xing, Yuki Shirari, Devesh Jha and Diego Romeres
ICRA 2026 Workshop on Dexterity with Multifingered Hands: Hardware, Sensing, and Skills, 2026
dexterous manipulationnon-prehensile manipulationguided diffusion
|
 |
Haowen Liu*, Shaoxiong Yao*, Haonan Chen, Jiawei Gao, Jiayuan Mao, Jia-Bin Huang and Yilun Du
IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), 2026
vision-language modelsreal-to-simphysical reasoningmanipulation planning
|
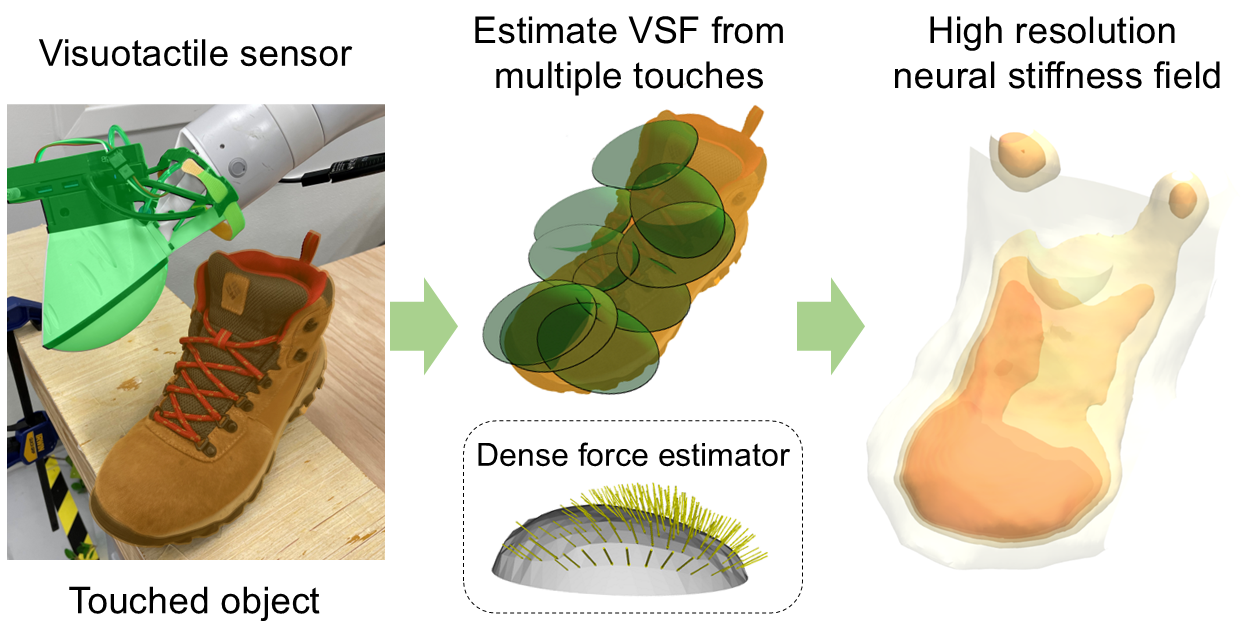 |
Jiaheng Han*, Shaoxiong Yao* and Kris Hauser
International Conference on Robotics and Automation (ICRA), 2025
tactile perceptionneural fieldsdeformable object modeling
|
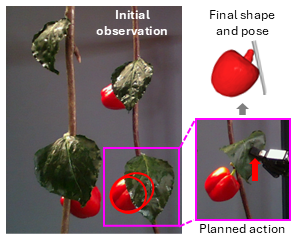 |
Shaoxiong Yao*, Sicong Pan*, Maren Bennewitz and Kris Hauser
International Conference on Robotics and Automation (ICRA), 2025
agricultural roboticsdeformable object manipulationshape completion
|
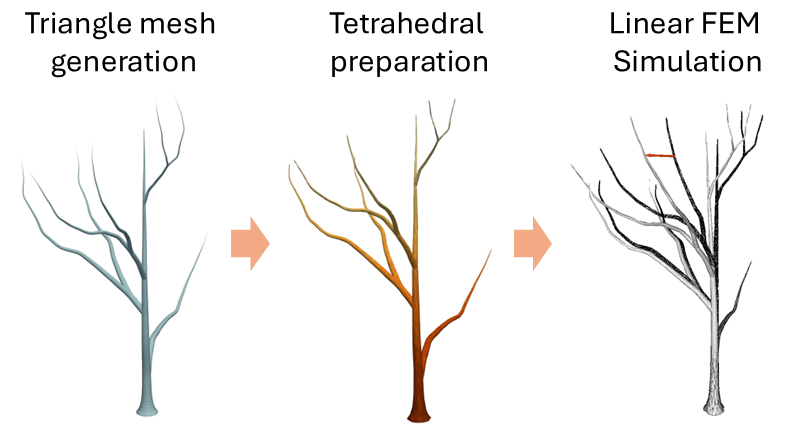 |
Shaoxiong Yao and Kris Hauser
IROS2024 Workshop on Agricultural Robotics for a Sustainable Future, 2024
physical modelingFEM simulationagricultural robotics
|
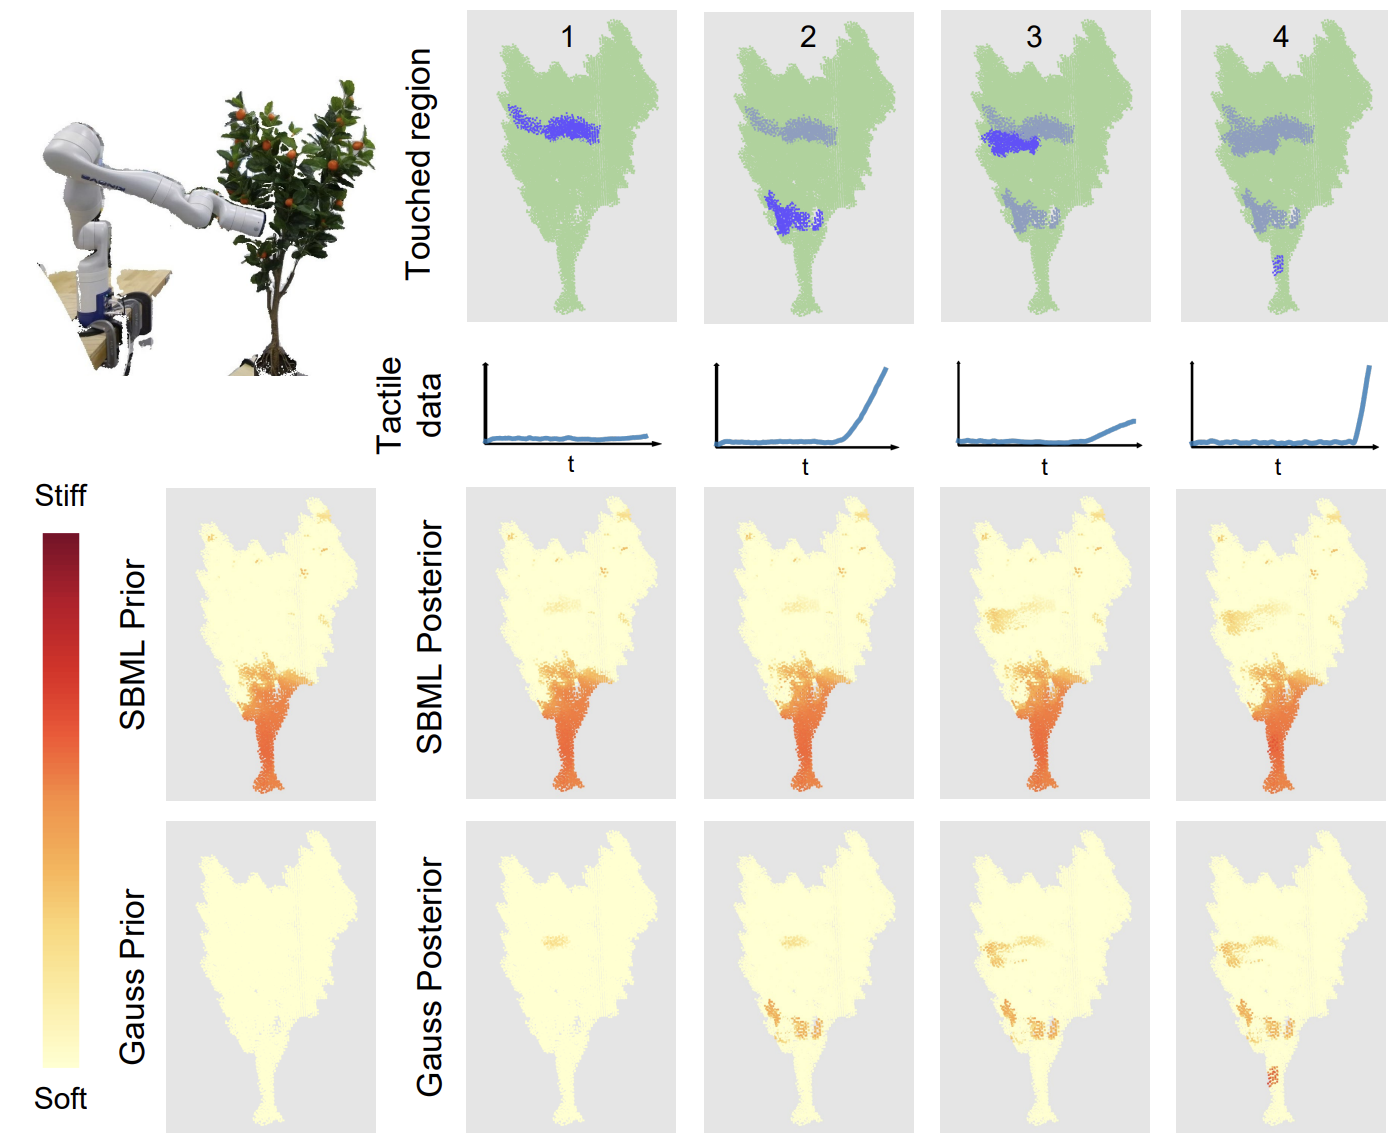 |
Shaoxiong Yao, Yifan Zhu and Kris Hauser
Conference on Robot Learning (CoRL), 2024
meta-learningvisual-tactile perceptiondeformable object modeling
|
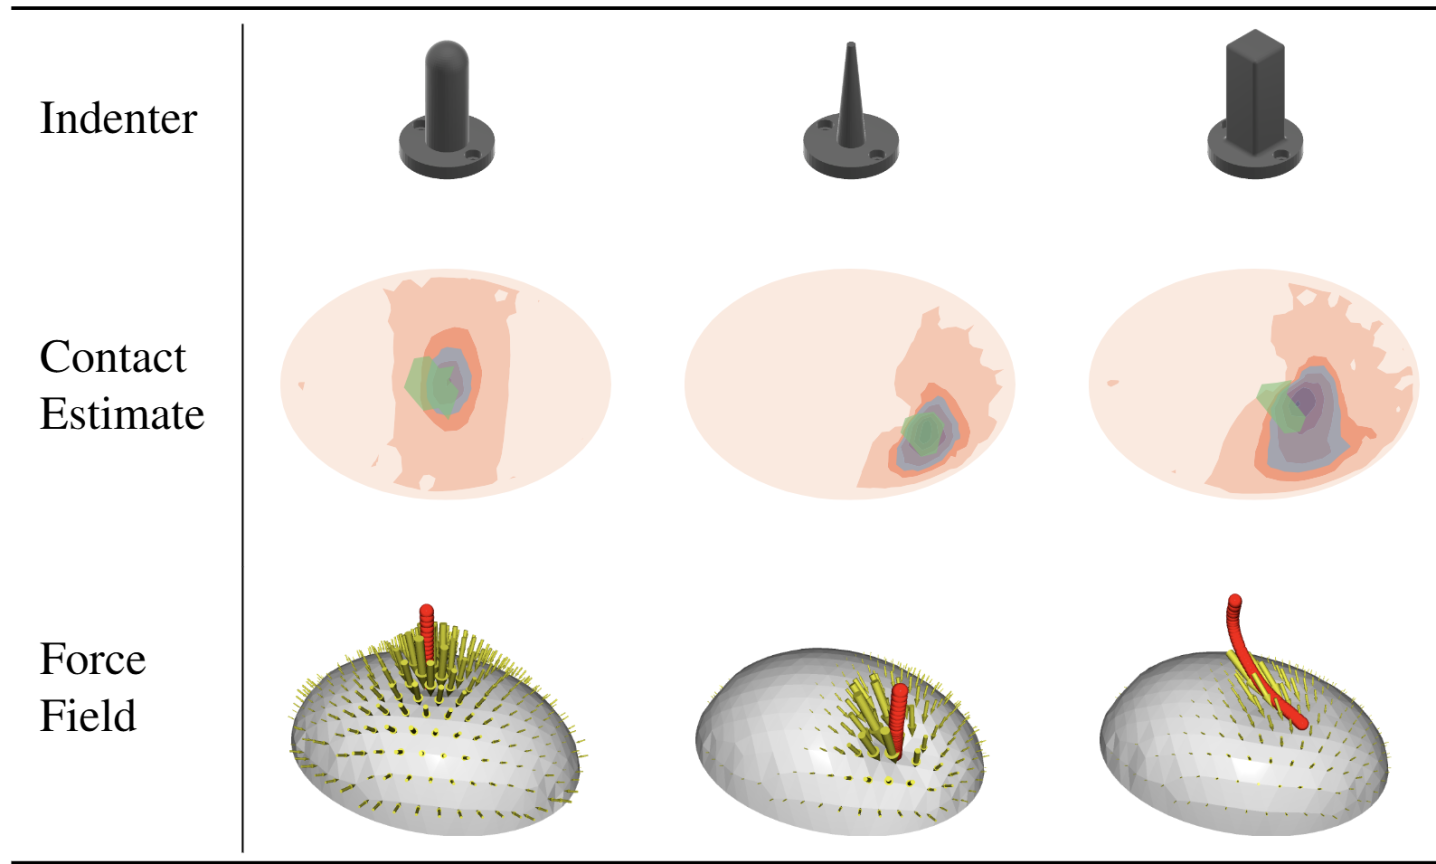 |
Jing-Chen Peng, Shaoxiong Yao and Kris Hauser
International Conference on Robotics and Automation (ICRA), 2024
tactile sensingFEMcontact force estimation
|
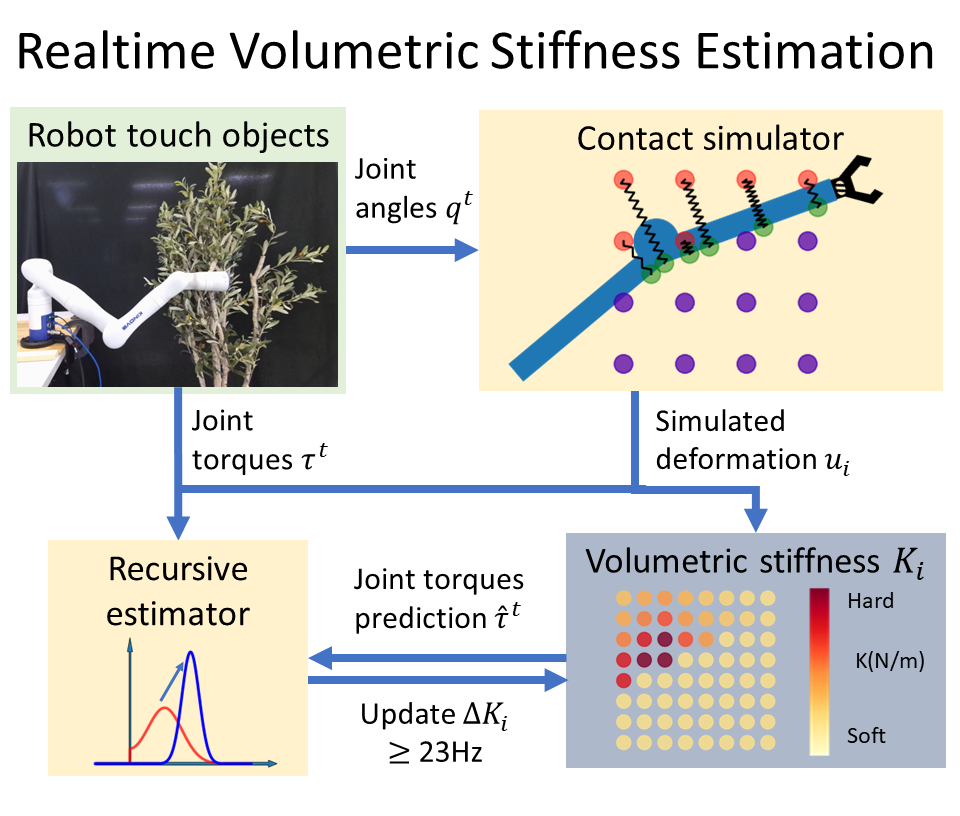 |
Shaoxiong Yao and Kris Hauser
International Conference on Robotics and Automation (ICRA), 2023
tactile perceptiondeformable object modelingreal-time estimation
|
|
|
 |
Instructional Aid, ROB101 Computational Linear Algebra Fall 2020 |
 |
Teaching Assistant, Vv214 Linear Algebra Spring 2019 |
|
I write notes, you may find one of them useful: linear algebra and multivariate calculus, underactuated robotics. I am an organizer of UIUC robotics seminar series. If you are interested in giving a talk, please contact me. I translated Prof. Steve LaValle's Bio into Chinese. |
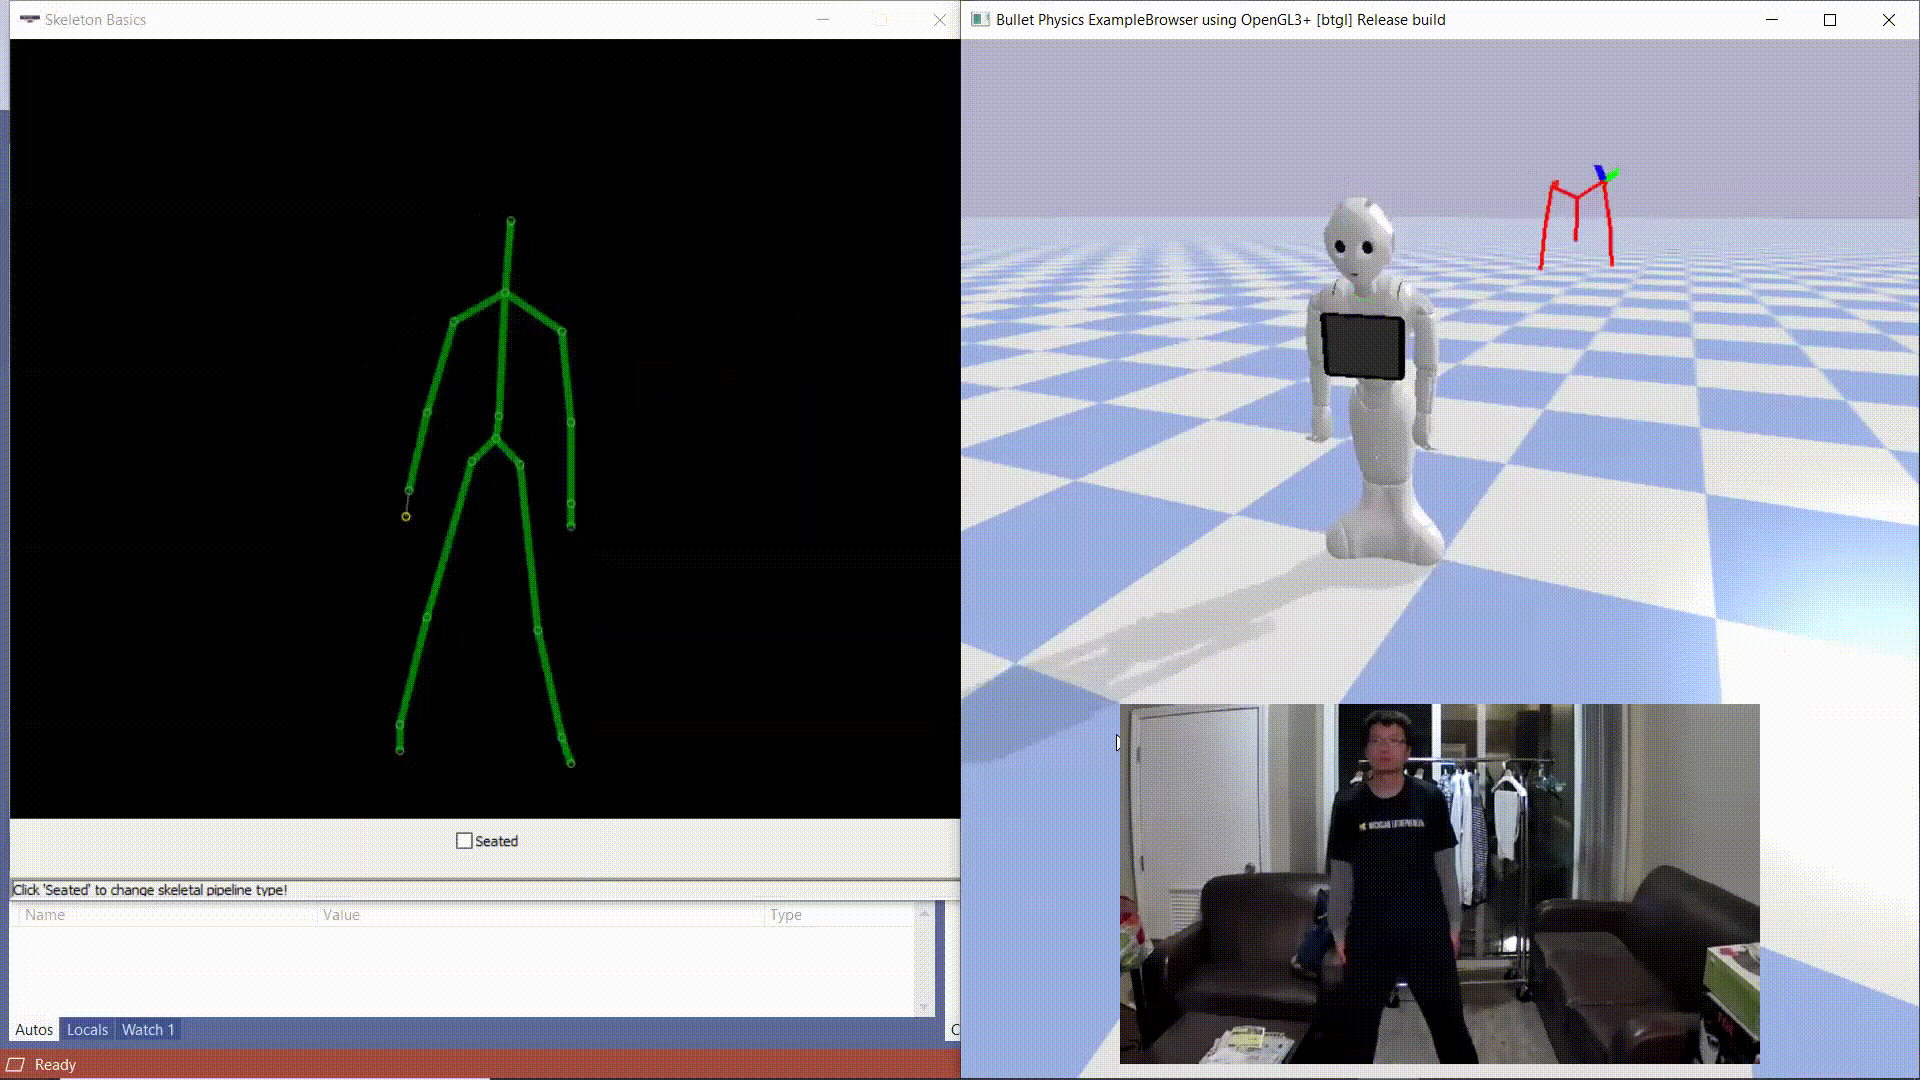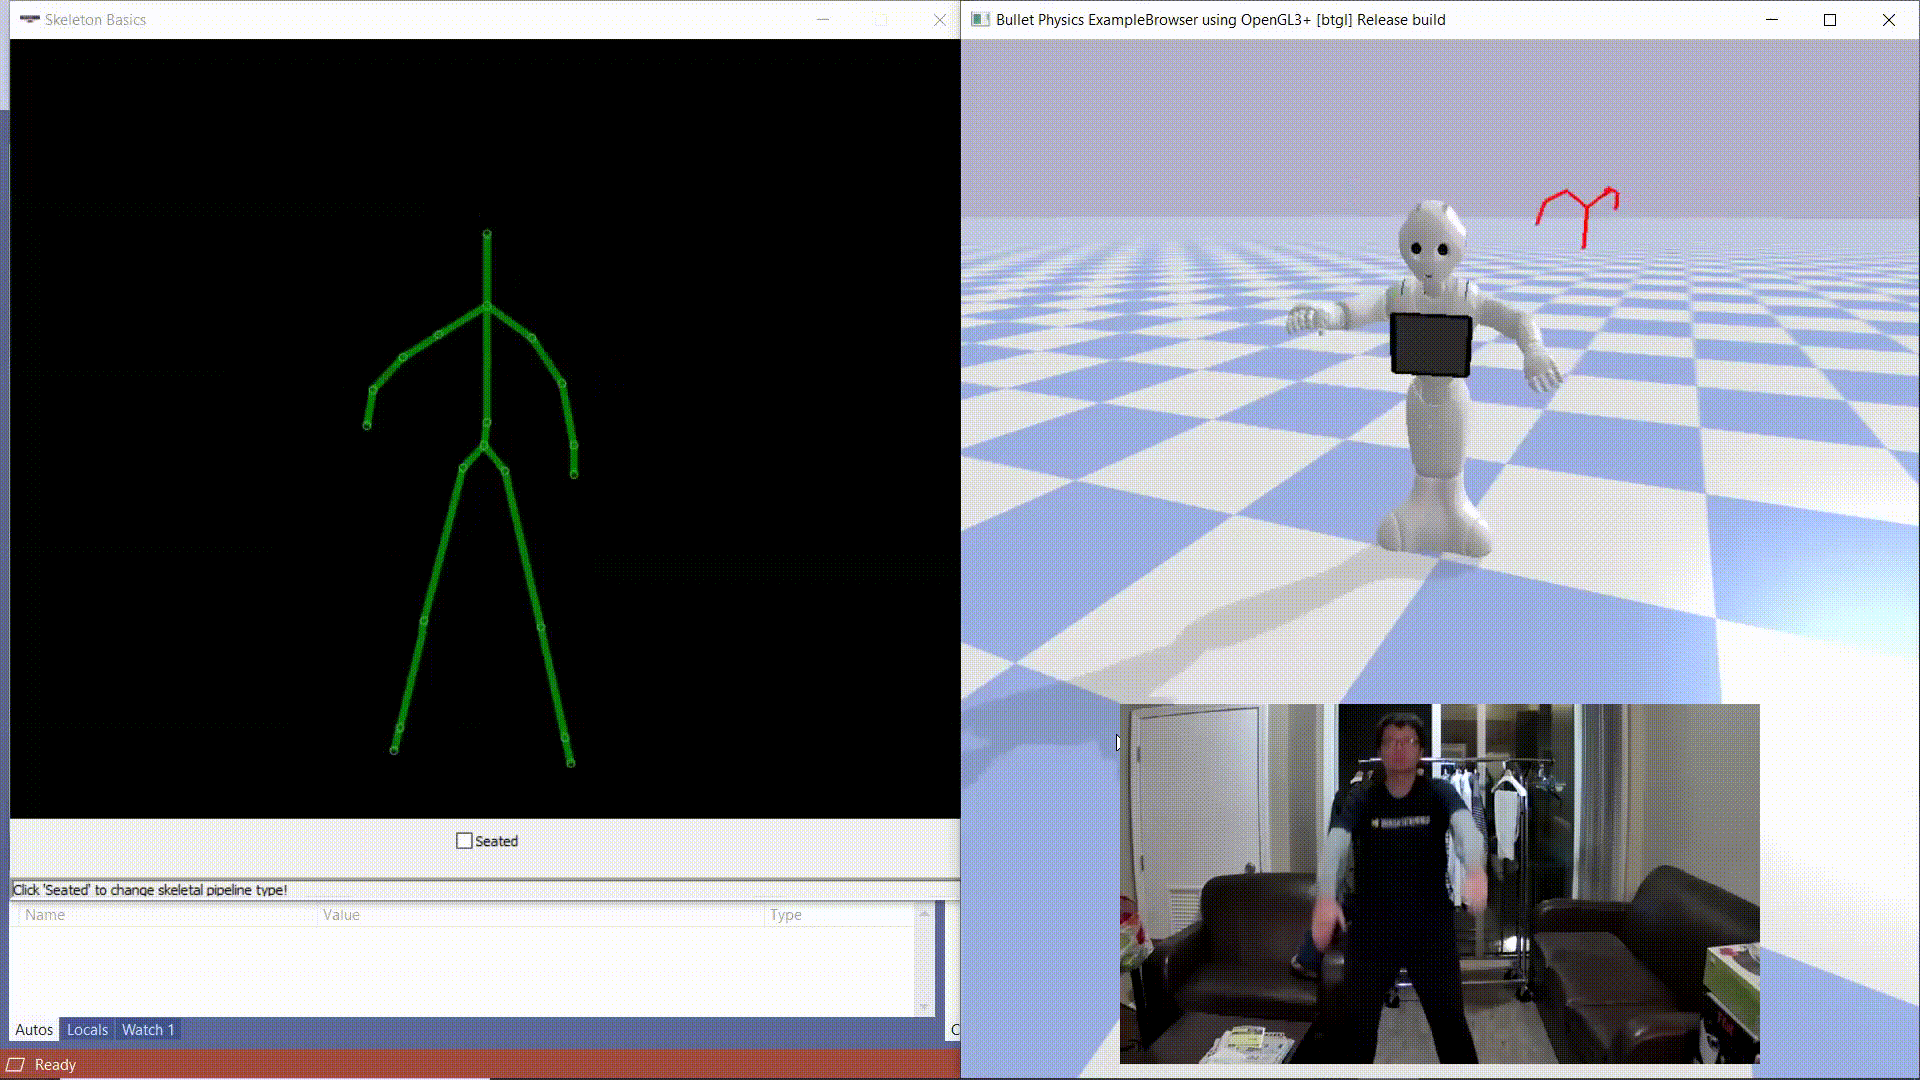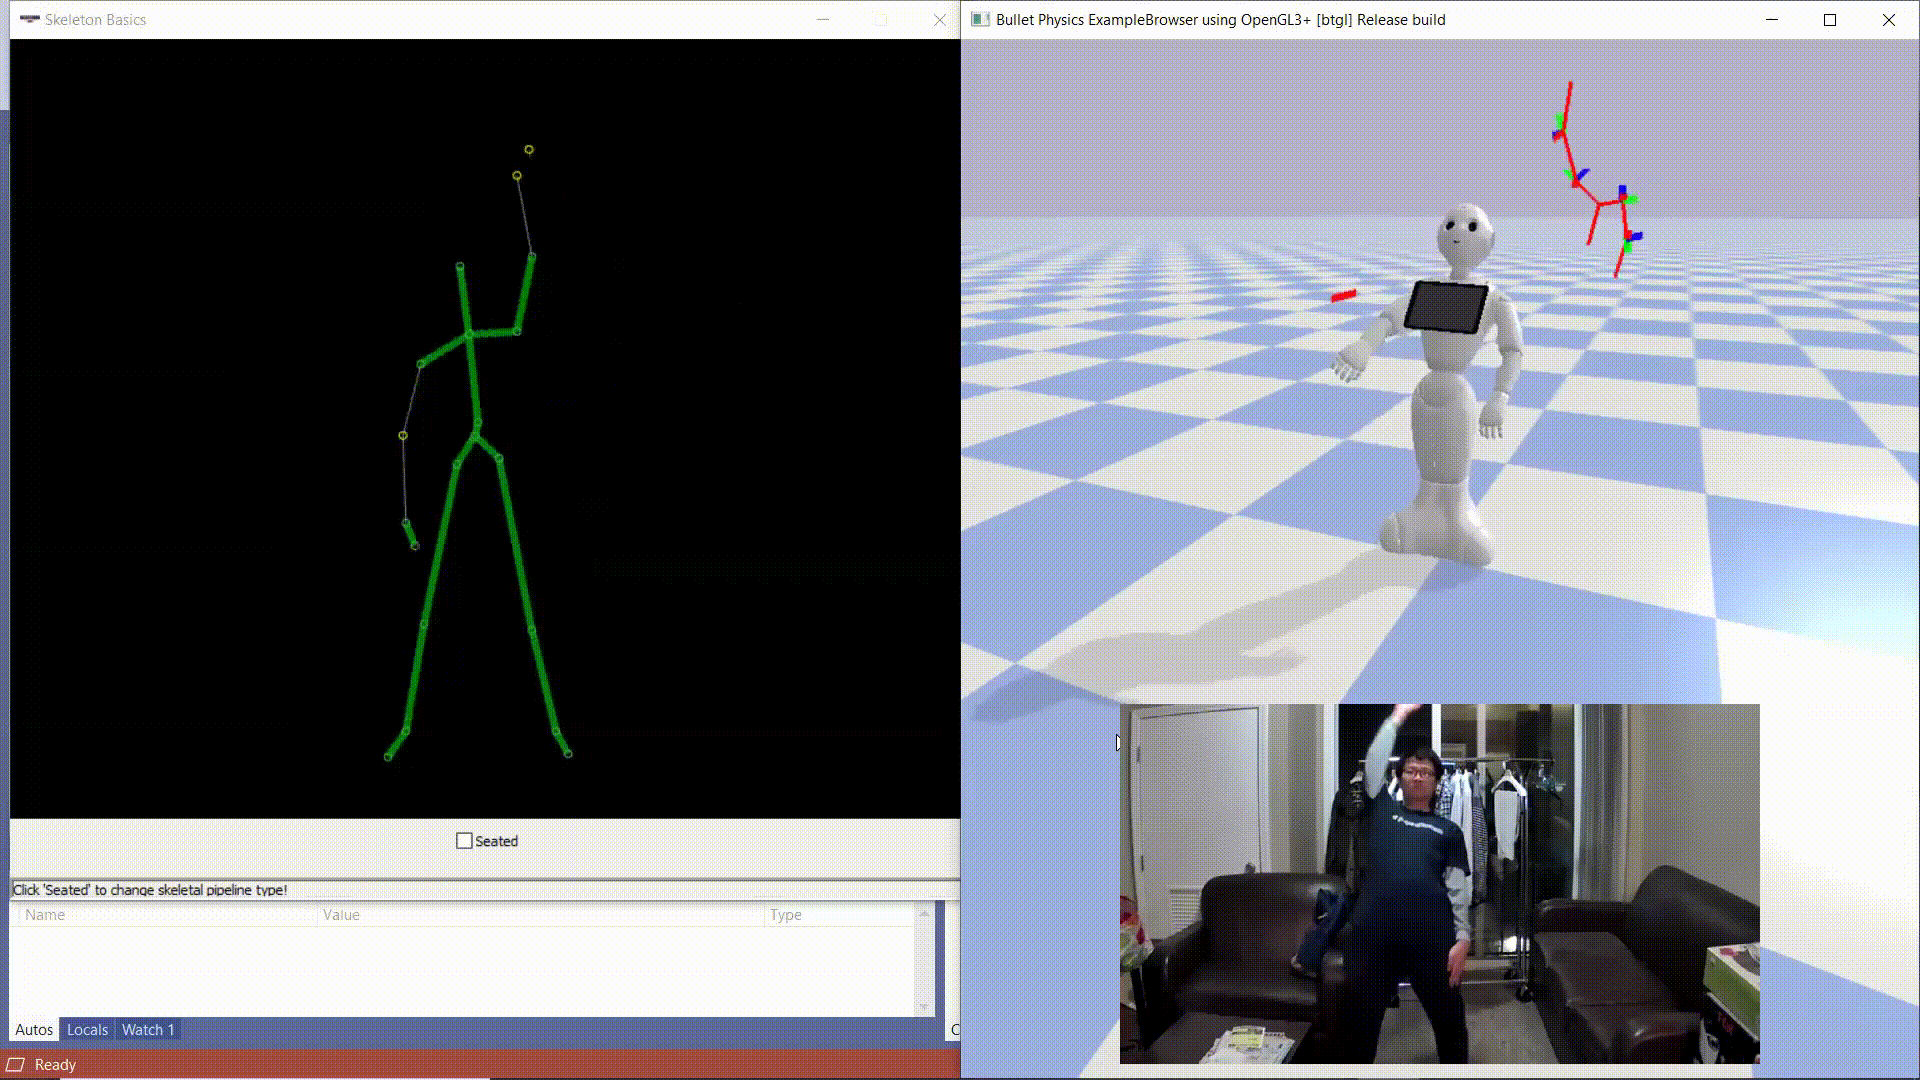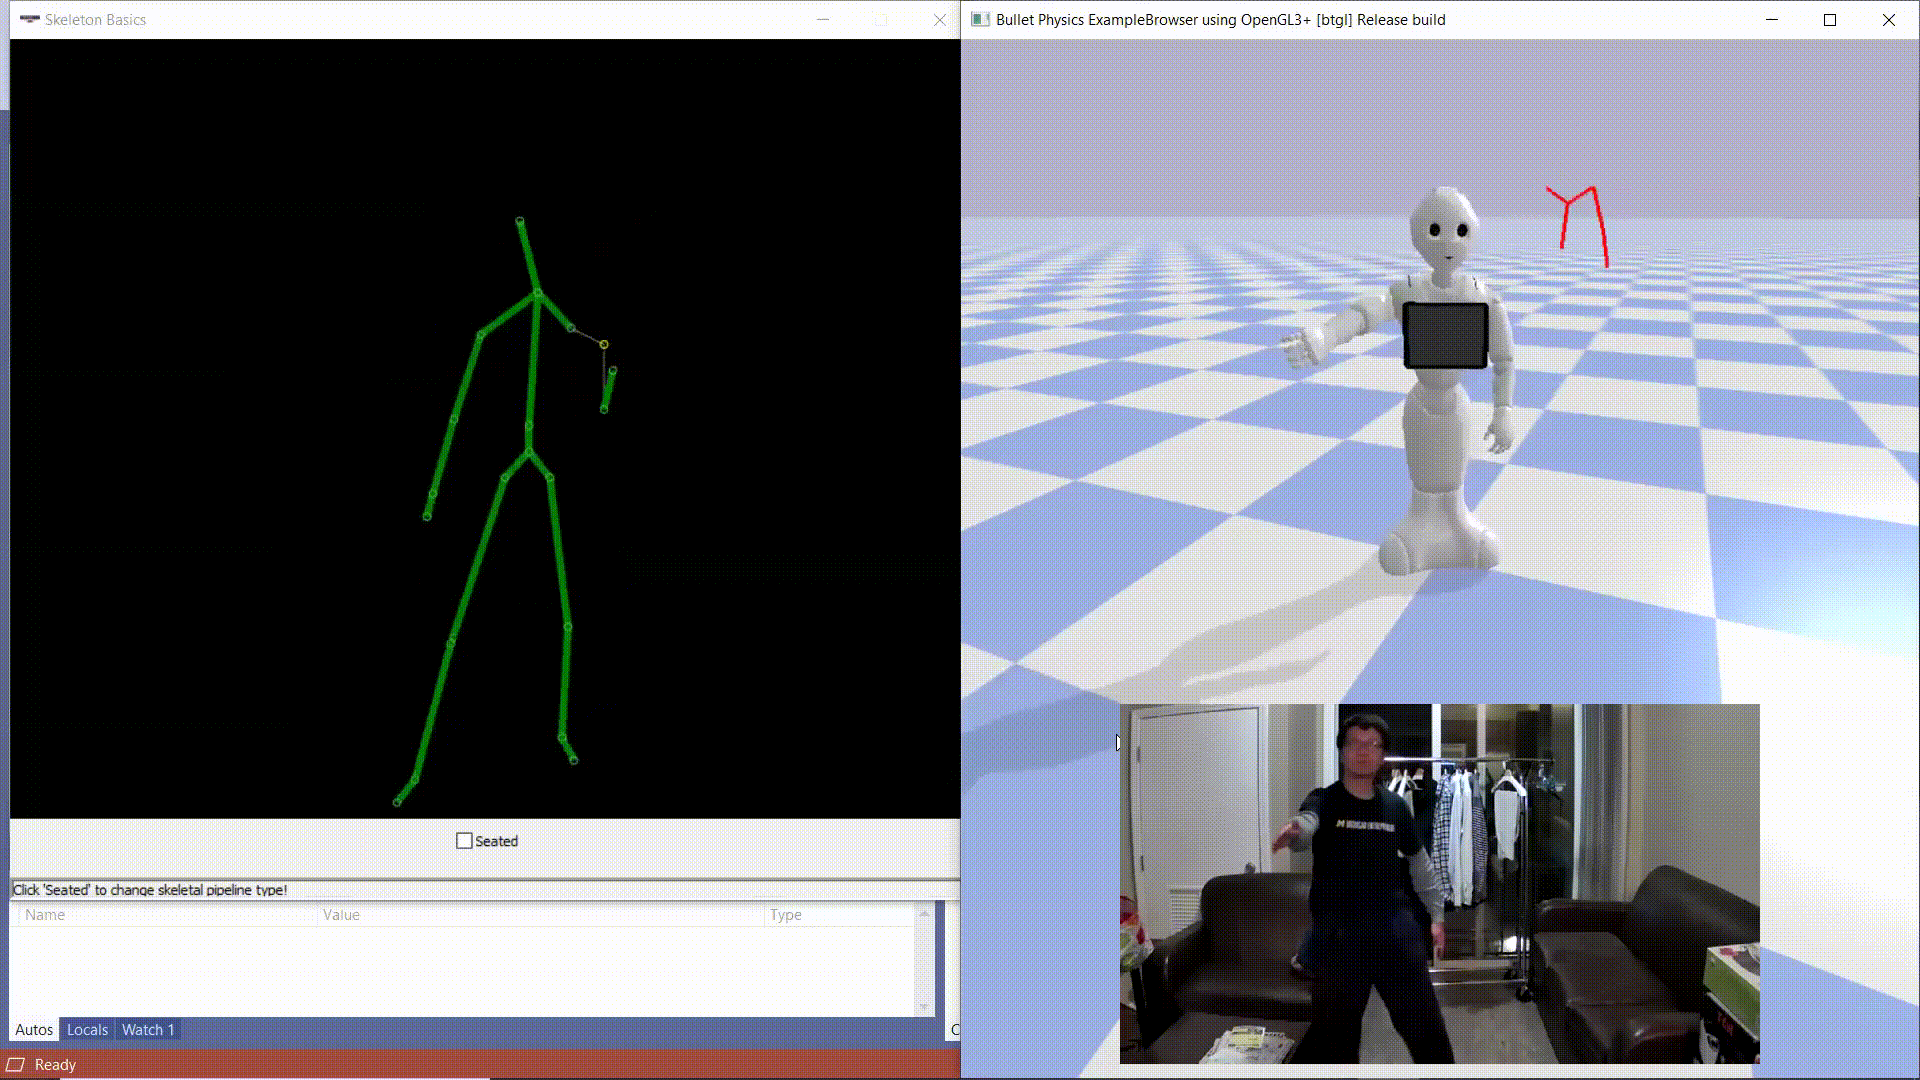 |
Teach your robot to dance, EECS467 Final Project Winter 2021 |
|
Updated in Nov. 2026. Thanks Jon Barron for this amazing template. |